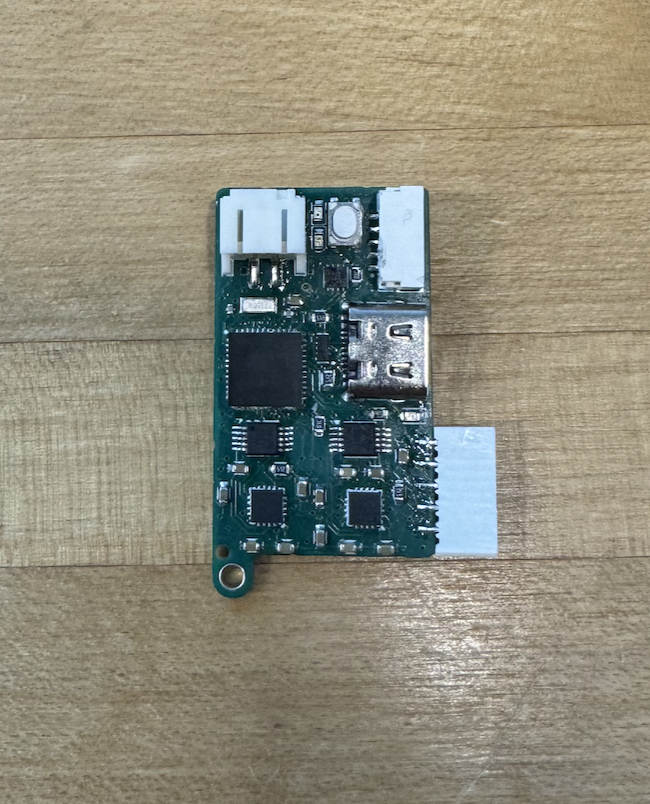
Lots of people have been making foot force sensors for some reason, so here’s mine!
Detecting foot pressure is really useful for lots of robots in the lab. One of the core problems is trying to understand what the user is actually trying to do; if you know where someone is trying to distribute force in their foot, then you can react to that easily! Even a binary on/off for detecting what ‘zone’ of the foot is getting the majority of the pressure is helpful, since it tells the robot what part of the gait the user is in.
My pressure sensor uses a force-sensitive-resistor (FSR) pad in the shape of a foot - actually, it’s a whole bunch of them laminated together.
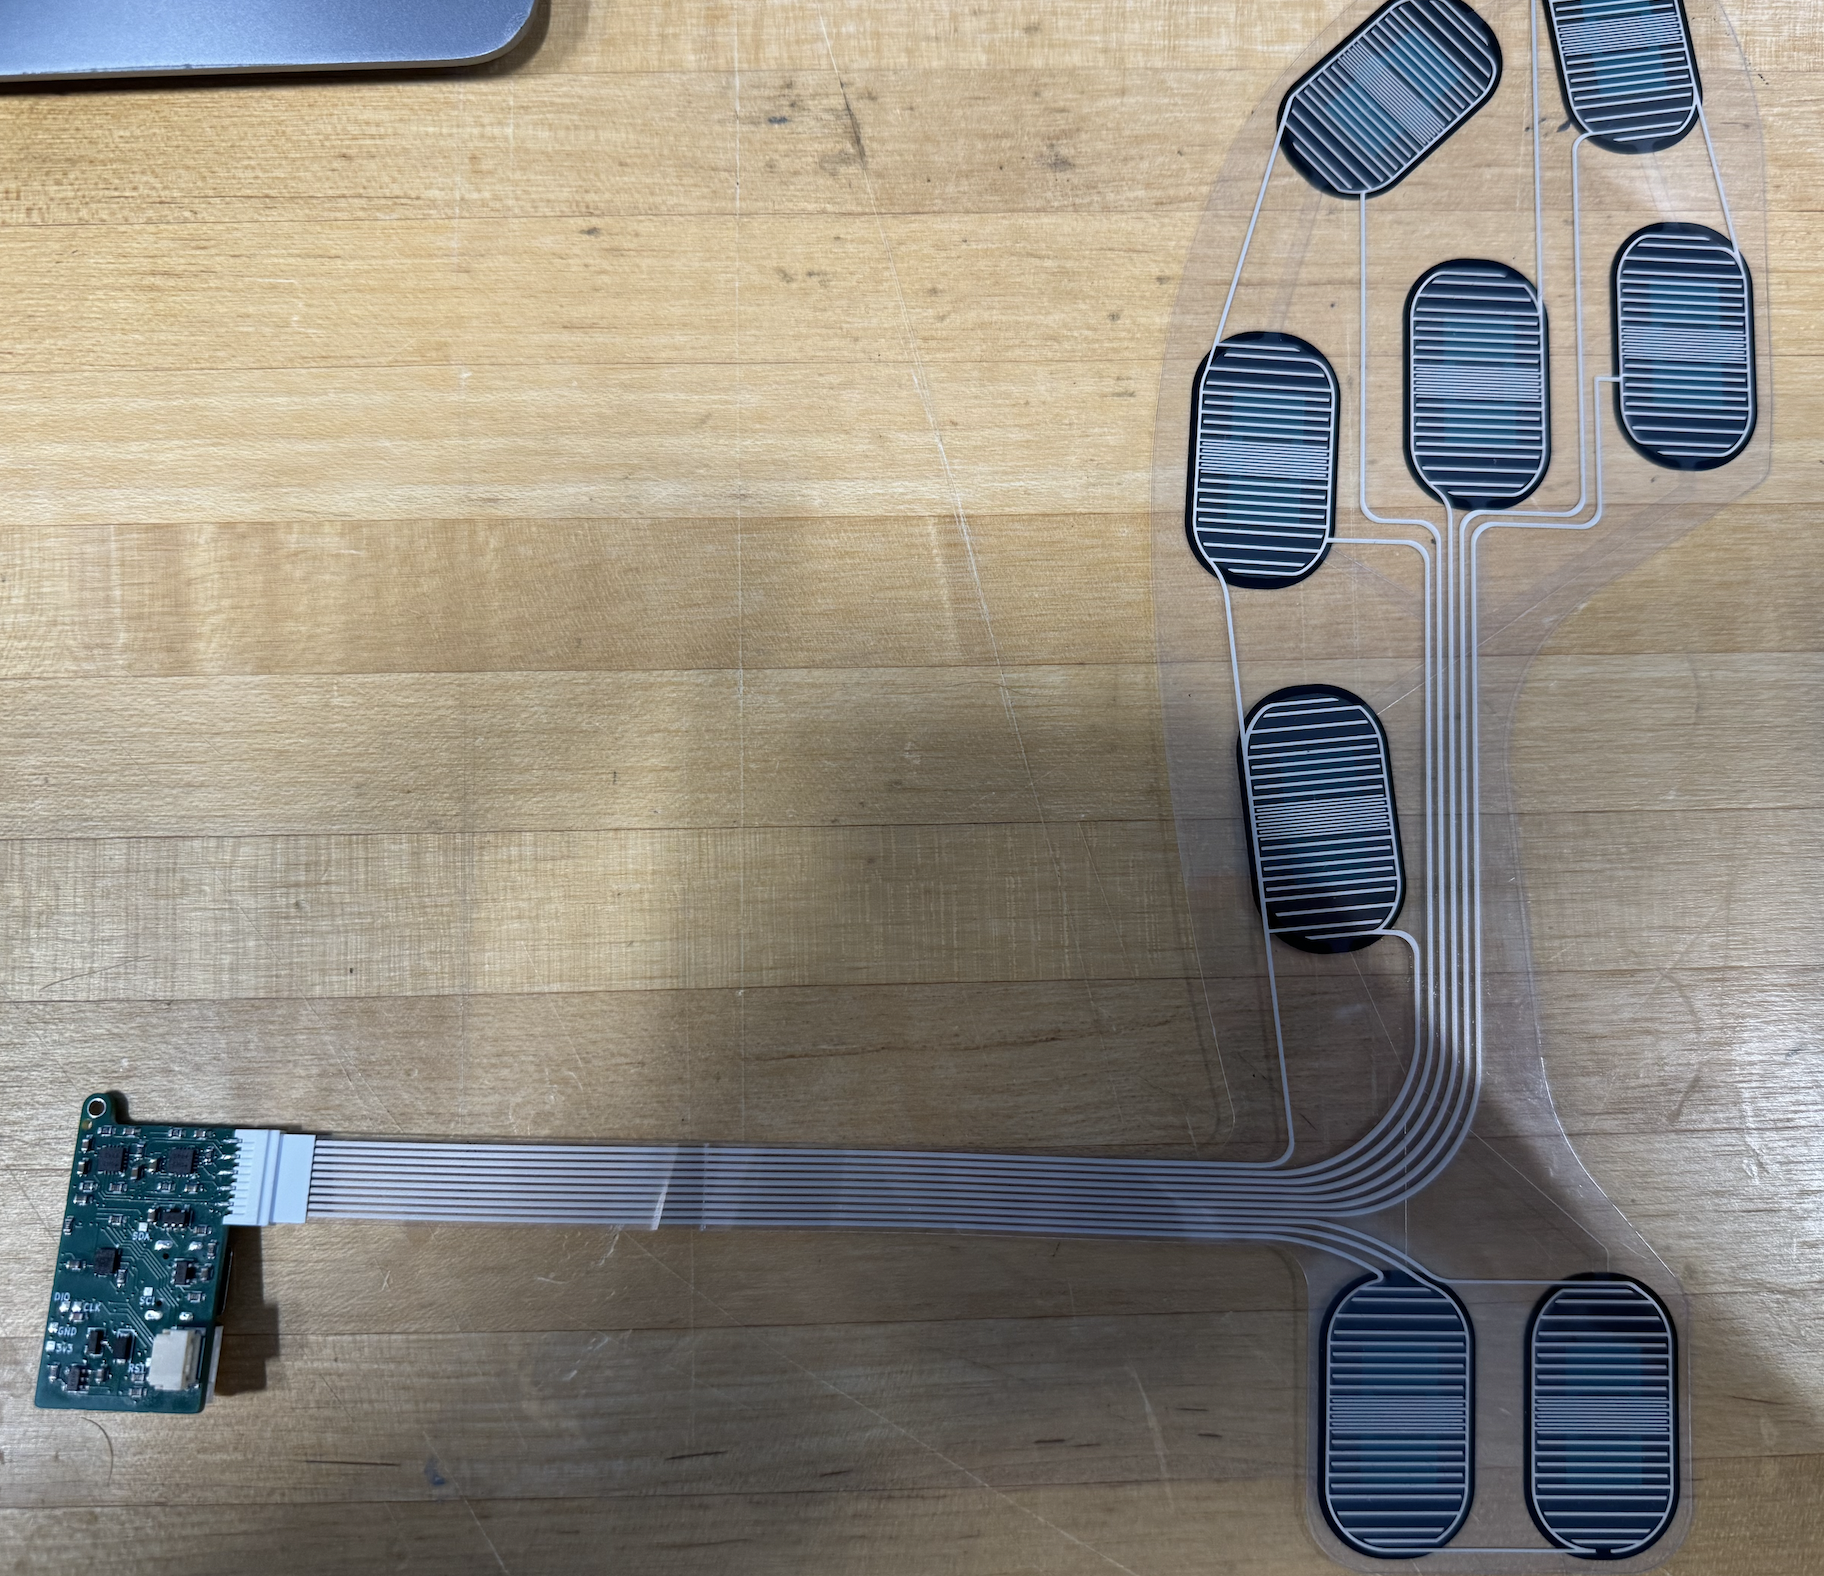
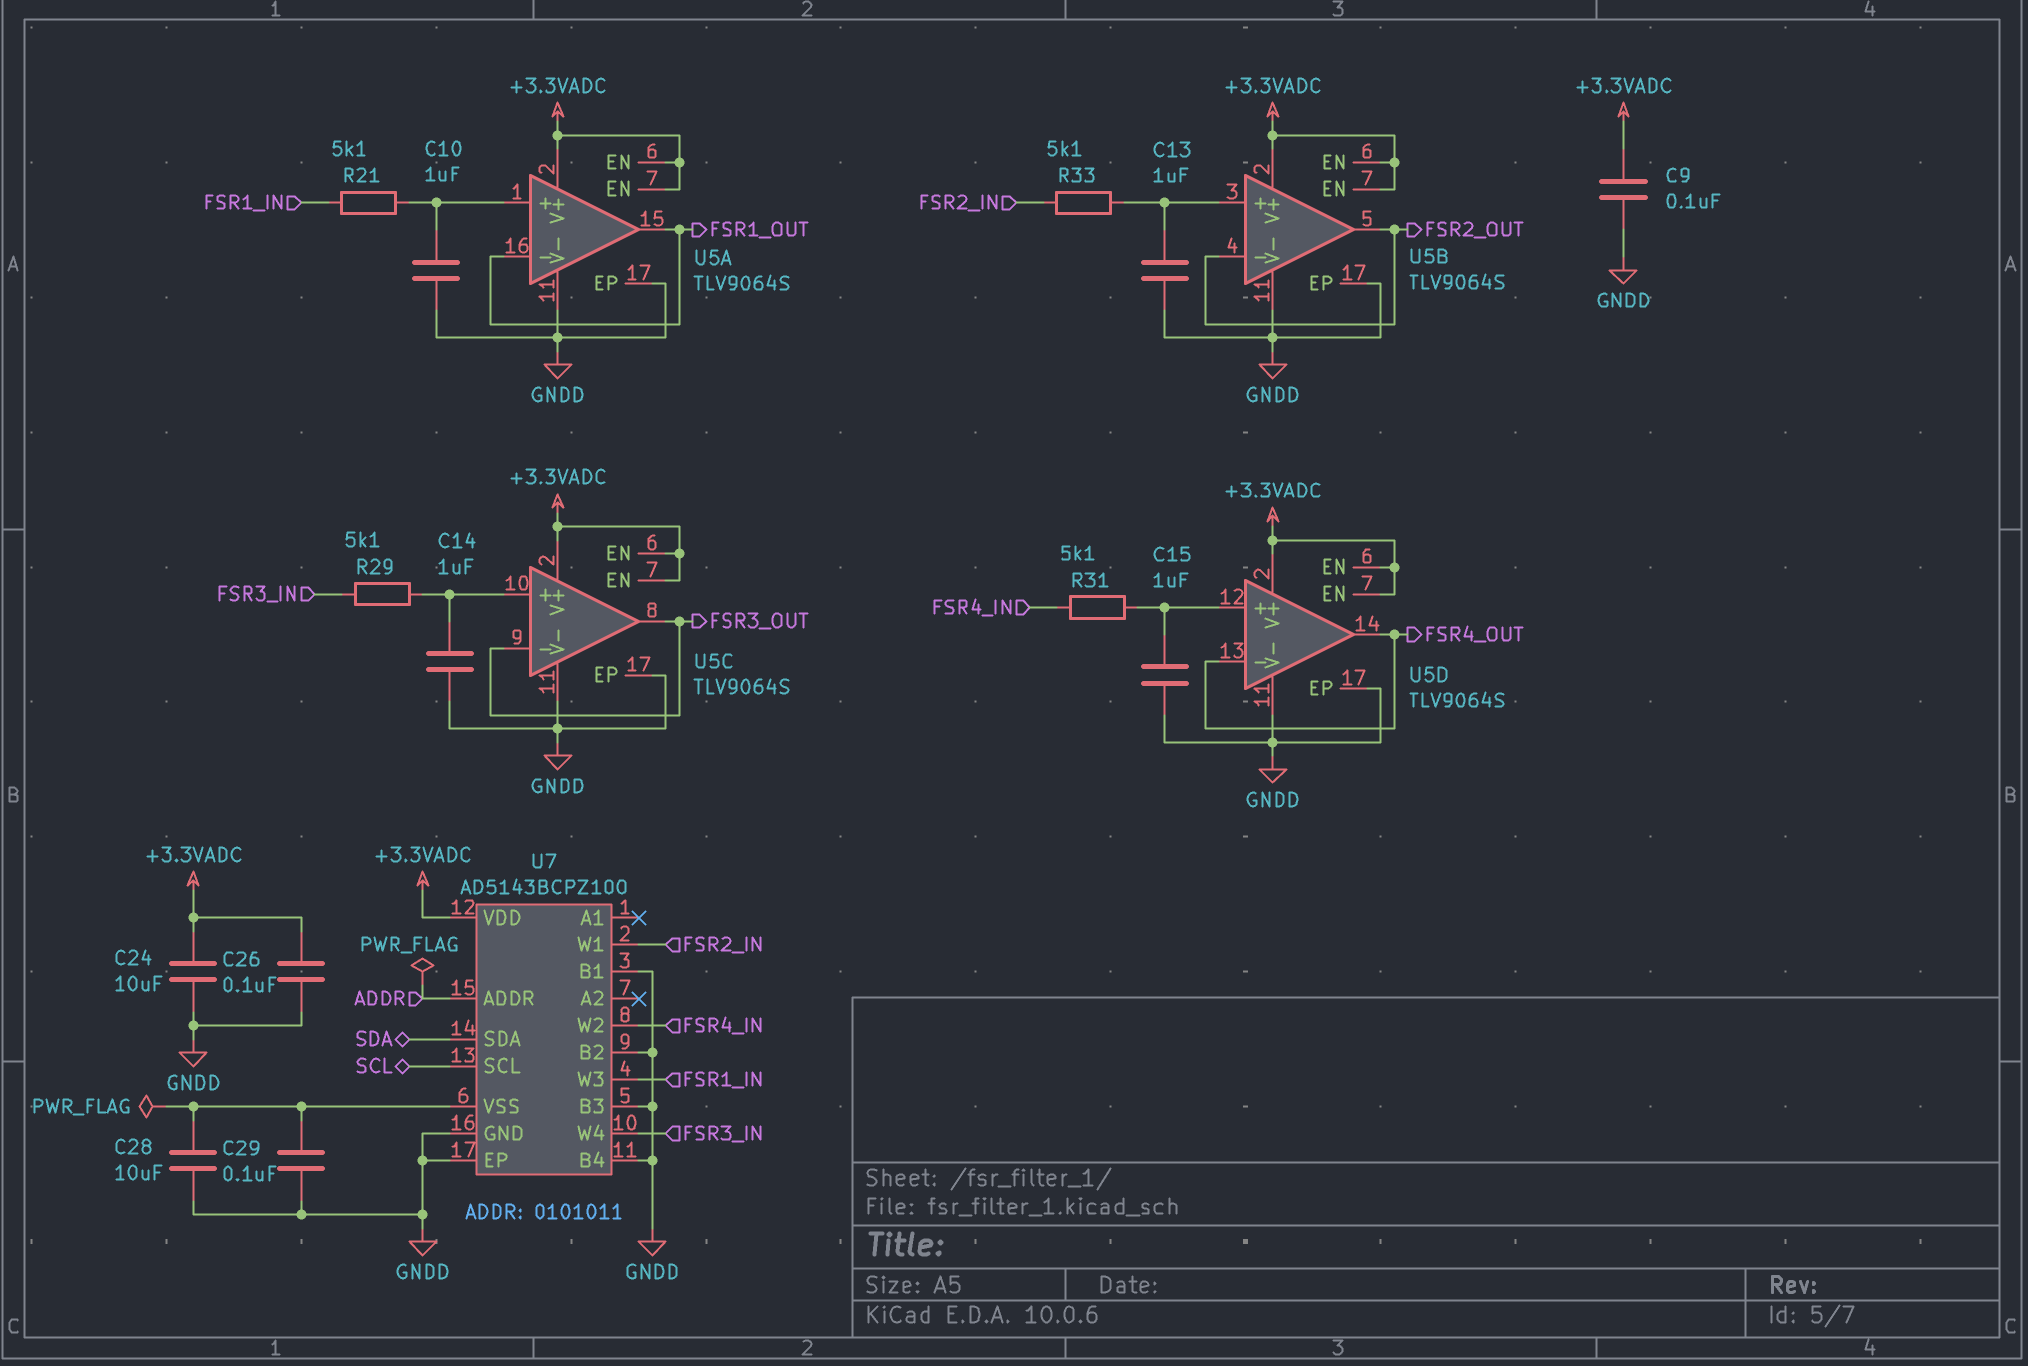
FSRs are really simple to use. The easiest thing to do is to put them in resistor divider configuration and measure the output voltage, but the output range can vary depending on how much the FSR resistance changes (a direct function of weight, ignoring temperature). To improve your SNR for different weights, it’s helpful to be able to configure what the counterpart to the FSR resistor is. I stuck some digital potentiometers on help with that.
The only other requirement is that this thing is compact. I designed a little case for it that also holds a battery to keep it powered. Battery life is a few hours.
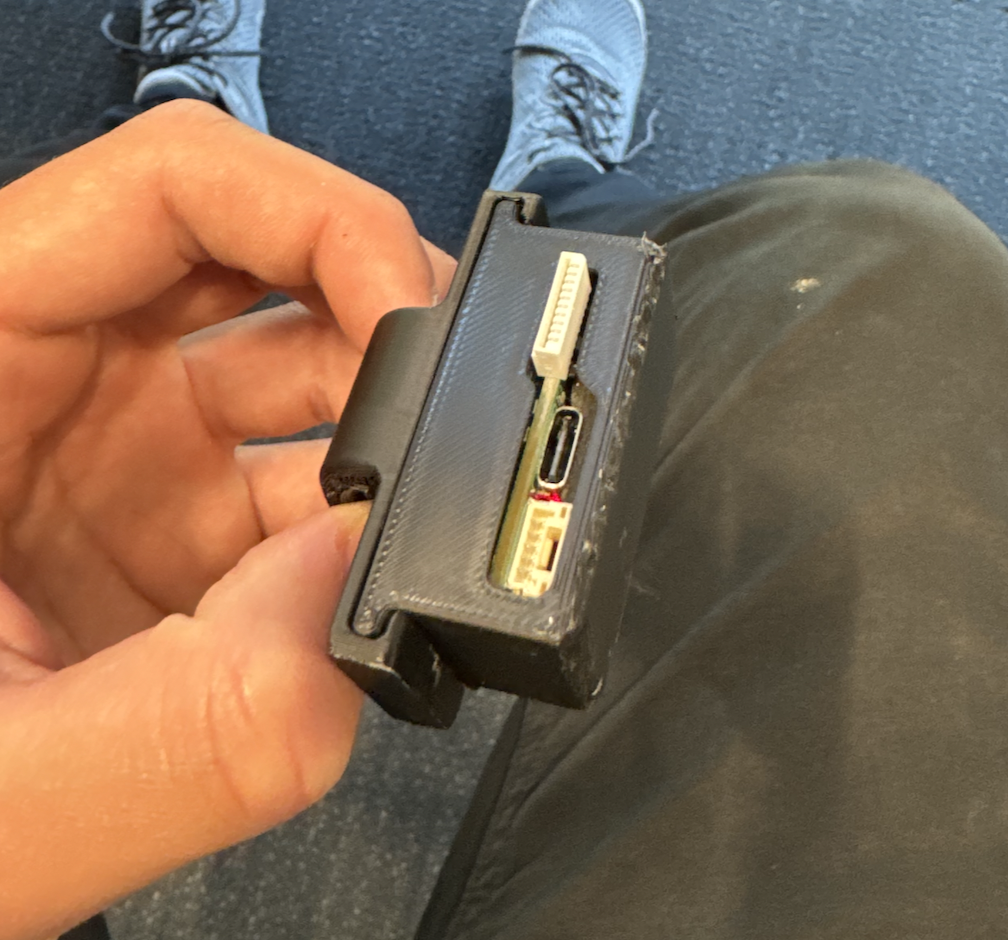
All the data is output over USB. I originally made a wifi version too (using esp32 platform), but that ended up being too slow, so I ended up making the smaller one you see here.
Here it is working! The script manually maps force data to location on the foot SVG, and color is modeled as a radial basis function about those points.